Mechanical design.
Physical prototypes.
Measured results.
My work connects mechanical engineering, sensing and programming—from estimating forces in surgical instruments to building and launching a two-ton tunneling machine.
Force sensing for surgical instruments
Master’s thesis / University Hospital Balgrist
Objective
Estimate instrument-tip forces from a proximally mounted sensor, without instrument modification.
Engineering approach
Integrated the proximal sensor and calibrated the instrument using reference loads from a haptic device. Implemented control in C++ / ROS 2 and evaluated force models in Python.
Results
71% lower error across 8 experiments
Swissloop Tunneling
Microtunnel boring machine / Student engineering association
Objective
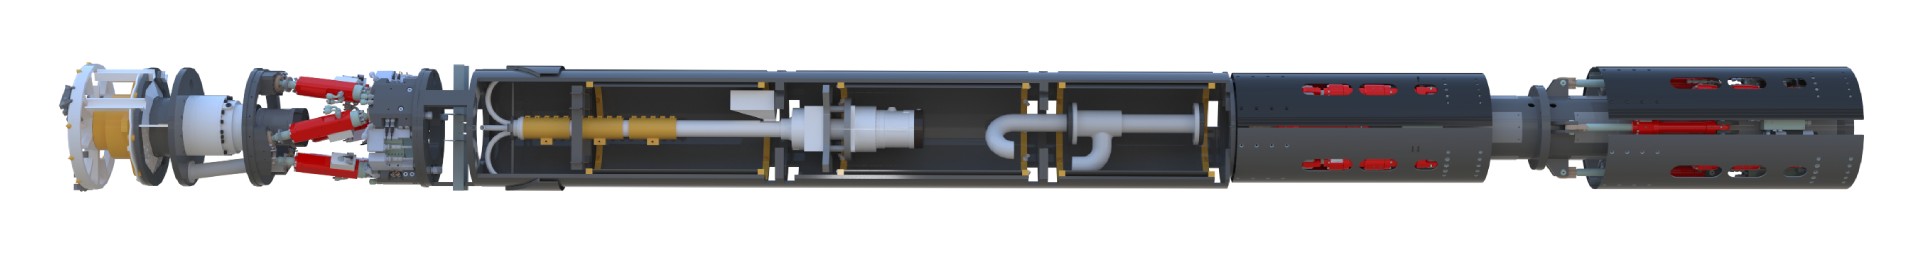
Develop an 8 m, 2 t microtunnel boring machine for the Not-a-Boring Competition.
Engineering approach
Designed subsystem assemblies in Siemens NX. Built metal and wood hardware using milling, turning, welding and laser cutting. Produced 3D-printed prototypes and coordinated subsystem development.
Results
Physical subsystem hardware and an integrated machine at competition.
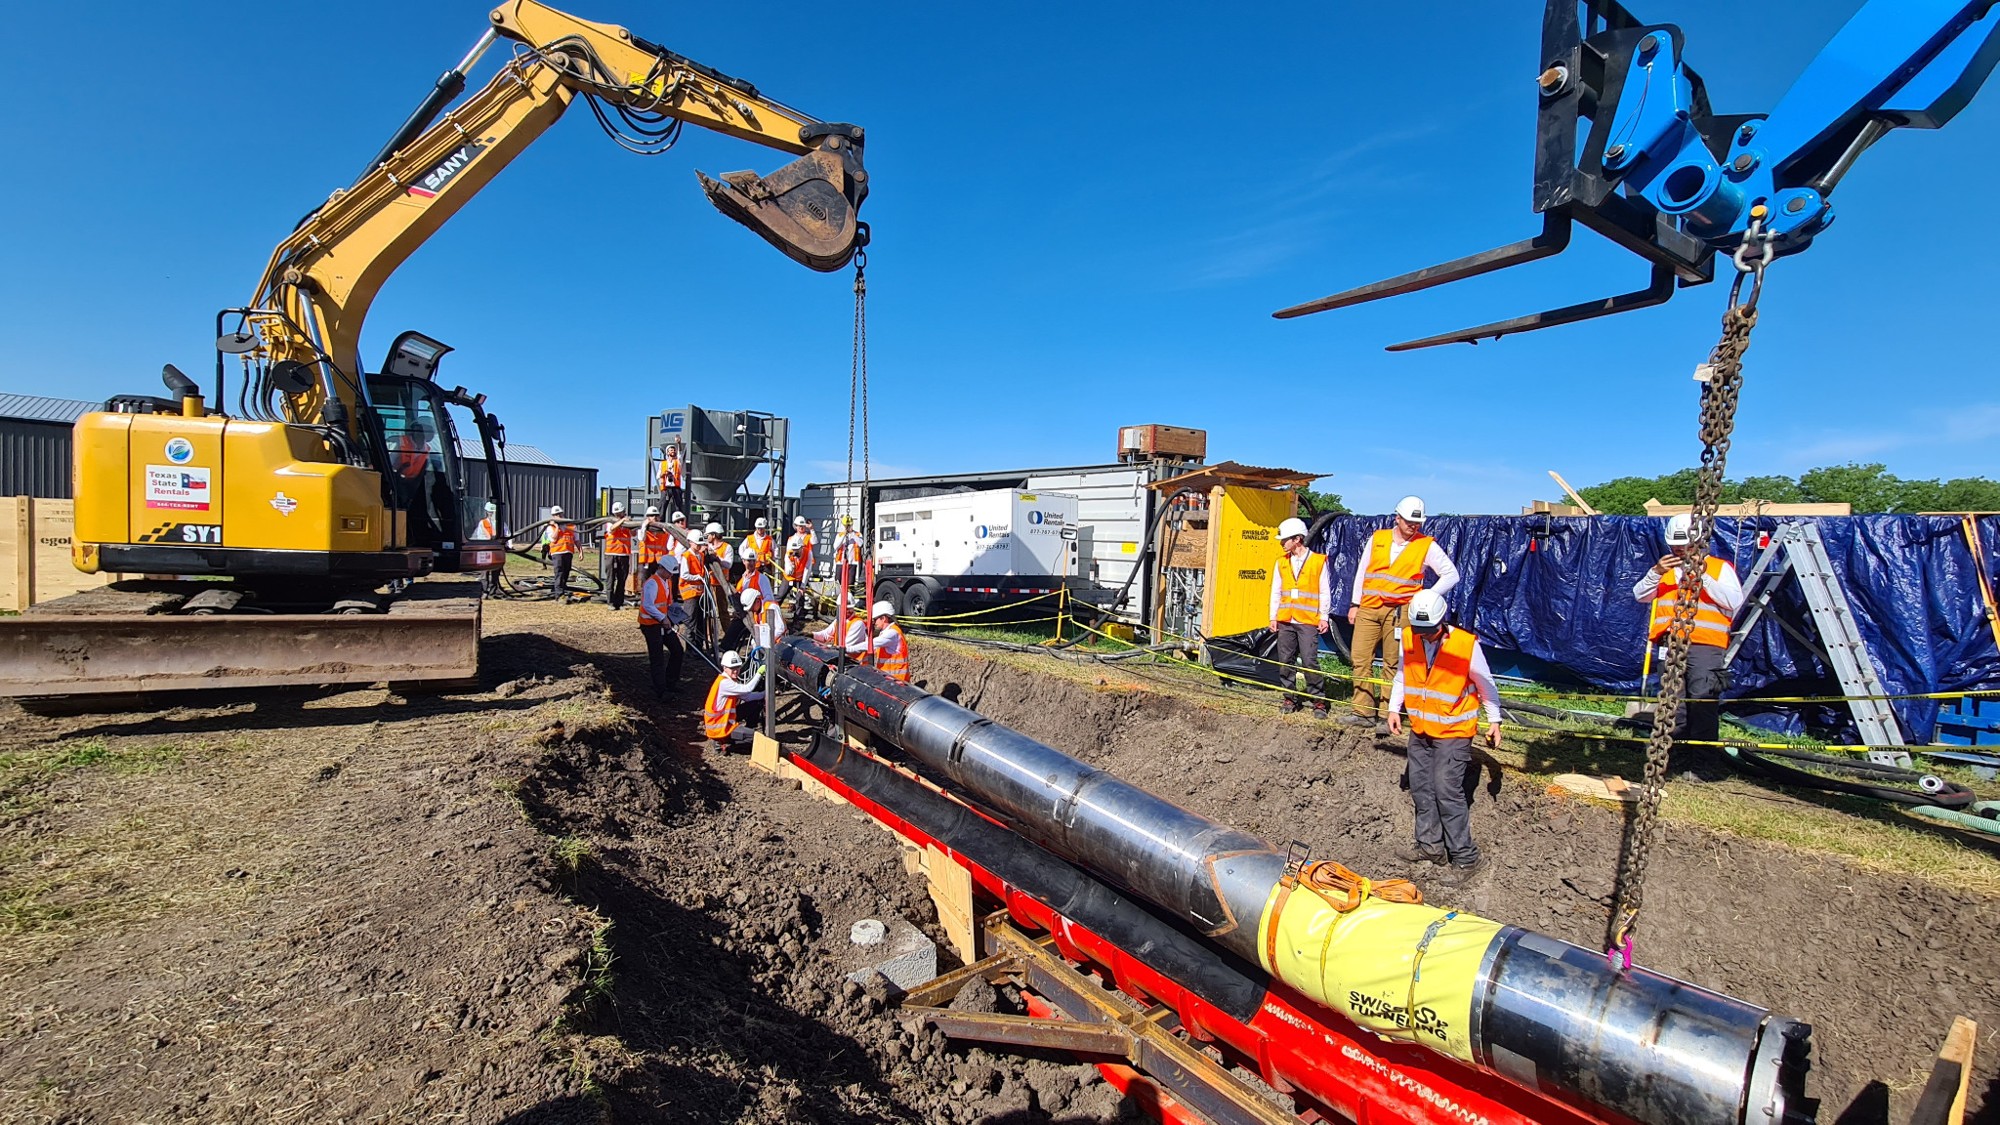
Launching platform
Swissloop Tunneling / Subsystem lead
Objective
Launch an 8 m, 2 t machine while retaining access for operation and transport.
Engineering approach
Led the platform subsystem. Calculated screw stresses and analyzed static loads and moments. Designed for operating access, transport and multiple functions.
Results
Field-tested launch procedure in dusty, rough conditions.
An anatomical lung phantom
Civilian service / KSA Medical Physics
Objective
Create an actuated lung phantom with reproducible, nonlinear motion.
Engineering approach
Wrote MATLAB code to generate fractal-inspired airway geometry. Parameterized initial branch diameter and branching depth, then exported STL geometry for SLA printing. Developed without LLM assistance.
Results
Prototype with a flexible SLA airway tree and 2 adjustable geometry inputs.
Programming & machine learning
Code applied to physical systems and biomedical data
Advanced ML
ETH / HS 2024
Python
Deep learning frameworks
Course projects: age prediction from MRI features using feature selection; ECG rhythm classification using signal features and class balancing; mitral valve segmentation in ultrasound images.
Force estimation
C++ / ROS 2
Python
Controlled the calibration device, analyzed 8 experiments and mapped proximal readings to instrument-tip forces. Reduced error from 1.4 N to 0.4 N.
Elbow-movement detection
Chest and wrist IMUs
Decision trees
Preprocessed sensor data, engineered movement features and implemented classifiers to distinguish flexion from extension for taVNS therapy. Reported accuracy: 80%.
Airway-tree generation
MATLAB
STL / SLA printing
Generated branching geometry with adjustable initial diameter and depth. Exported an STL and printed the flexible structure. Developed without LLM assistance.
Gait dataset & clustering
Data preprocessing
Unsupervised clustering
Cleaned and processed gait measurements, defined relevant features and assembled a reusable dataset. Applied preliminary clustering to explore gait patterns after incomplete spinal cord injury. Developed without LLM assistance.
About
Albin Punnilathil
MSc Mechanical Engineering
ETH Zürich
I work across mechanical design, hands-on manufacturing and data analysis. These projects bring together the parts of engineering I enjoy: understanding a physical problem, building a solution and measuring how well it works.